Prasanth Kotaru

Prasanth Kotaru

Roboticist

Experience

  • Waymo
  • Tesla
  • Monarch Tractor

Education

Ph.D., Mechanical Engineering, University of California, Berkeley, CA, 2022

Dissertation: Dynamics and Control for Collaborative Aerial Manipulation

M.S., Mechanical Engineering, Carnegie Mellon University, Pittsburgh, PA, 2017

B.Tech., Mechanical Engineering, Indian Institute of Technology, Madras, India, 2014

Publications

Dissertation2022

Dynamics and Control for Collaborative Aerial Manipulation

Prasanth Kotaru

PhD Dissertation

ArXiv2023

Tethered Power for a Series of Quadcopters: Analysis and Applications

Karan P. Jain*, Prasanth Kotaru, Massimiliano de Sa, Koushil Sreenath, Mark W. Mueller

arXiv

Journal2020

Differential Flatness based Path Planning with Direct Collocation on Hybrid Modes for a Quadrotor with a Cable-Suspended Payload

Jun Zeng, Prasanth Kotaru, Mark Mueller, Koushil Sreenath

IEEE Robotics and Automation Letters (RA-L)

Journal2020

Geometric L₁ Adaptive Attitude Control for a Quadrotor Unmanned Aerial Vehicle

Prasanth Kotaru, Ryan Edmonson, Koushil Sreenath

ASME Journal of Dynamic Systems, Measurement, and Control

Conference2020

Multiple quadrotors carrying a flexible hose: dynamics, differential flatness and control

Prasanth Kotaru, Koushil Sreenath

IFAC World Congress

Conference2020

Ball Juggling on the Bipedal Robot Cassie

Katherine L. Poggensee*, Albert H. Li*, Daniel Sotsaikich*, Bike Zhang, Prasanth Kotaru, Mark Mueller, Koushil Sreenath

European Control Conference (ECC)

Variation Based Extended Kalman Filter on S²
Conference2019

Variation Based Extended Kalman Filter on S²

Prasanth Kotaru, Koushil Sreenath

European Control Conference (ECC)
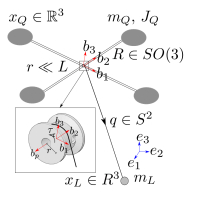
Geometric Control and Differential Flatness of a Quadrotor UAV with Load Suspended from a Pulley
Conference2019

Geometric Control and Differential Flatness of a Quadrotor UAV with Load Suspended from a Pulley

Jun Zeng, Prasanth Kotaru, Koushil Sreenath

American Control Conference (ACC)
Conference2018

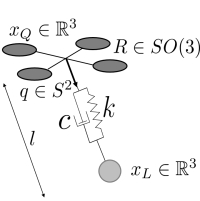
Differential-Flatness and Control of Quadrotor(s) with a Payload Suspended through Flexible Cable(s)

Prasanth Kotaru, Guofan Wu, Koushil Sreenath

Indian Control Conference (ICC)

Dynamics and Control of a Quadrotor with a Payload Suspended through an Elastic Cable
Conference2017

Dynamics and Control of a Quadrotor with a Payload Suspended through an Elastic Cable

Prasanth Kotaru, Guofan Wu, Koushil Sreenath

American Control Conference (ACC)